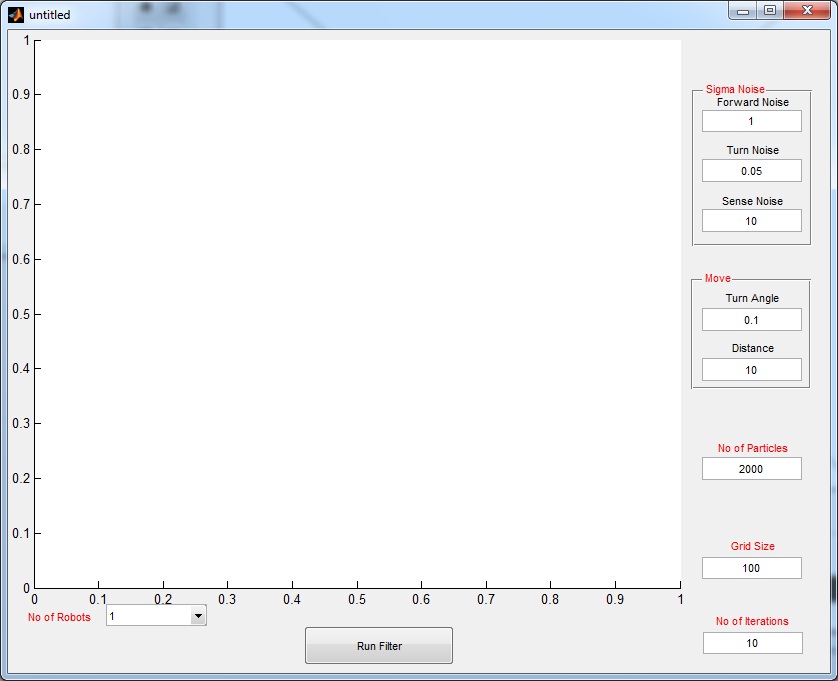
A Simple Particle Filter Simulator for Robot Localization
Simulates a robot in a known Map(re Sizable) but at an unkown location

You are now following this Submission
- You will see updates in your followed content feed
- You may receive emails, depending on your communication preferences
Cite As
Michael Mathew (2026). A Simple Particle Filter Simulator for Robot Localization (https://in.mathworks.com/matlabcentral/fileexchange/44117-a-simple-particle-filter-simulator-for-robot-localization), MATLAB Central File Exchange. Retrieved .
General Information
- Version 1.3.0 (15.5 KB)
MATLAB Release Compatibility
- Compatible with any release
Platform Compatibility
- Windows
- macOS
- Linux

